Keyboard: arrow keys move the gripper, hold Shift to move faster, Enter adds a program point, Esc clears the program. In manual mode the arrows move the gripper by 1 mm, with Shift by 10 mm; angles and coordinates are typed into the fields below the panel. In path mode a line is drawn with the mouse or a finger, Esc erases it.
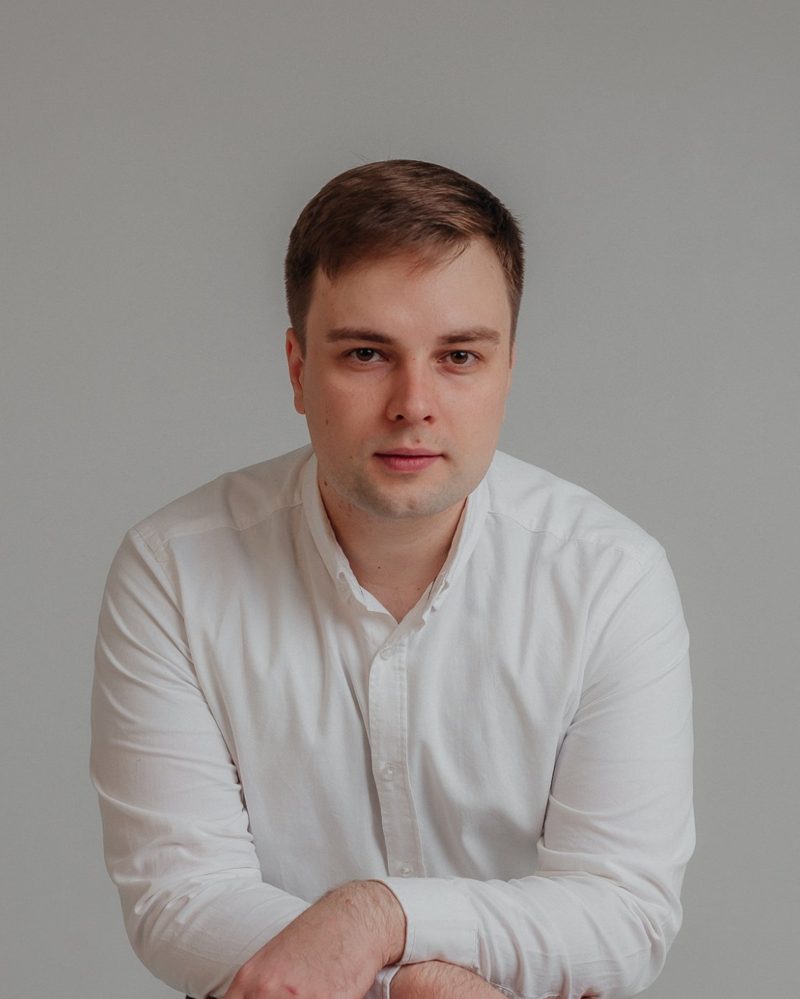
MaksimShevchenko
Robotics engineer and lecturer. I design robots, program them, and teach students to do the same.
About
I have worked in robotics for more than eleven years. I started at RSC Energia doing R&D in space robotics, then moved into universities.
Today I teach at Bauman Moscow State Technical University and Moscow State University of Technology “STANKIN”, supervise student projects, and teach an English-language course on industrial robots abroad. I also write professional training programs for engineers.
What interests me is where a robot meets a real task: an arm on the shop floor or a mobile platform that finds its own way. In teaching, what matters most to me is that my students can work with real equipment as soon as they graduate.
Path
-
RSC EnergiaR&D in space robotics.
-
Bauman Moscow State Technical UniversityStudied robotics and mechatronics; now teach there.
-
STANKINTeaching, a robotics lab, and a student robotics bureau: teams, mobile platforms, competitions. The bureau’s team placed at RSC Energia’s engineering hackathon.
-
Teaching abroadAn English-taught course on programming and operating industrial robots.
What I work with
Industrial robots
- ABB RobotStudio
- FANUC
- KUKA
- Collaborative robots
Mobile robots
- ROS 2
- Nav2
- Gazebo
- Computer vision, OpenCV
Programming
- Python
- C++
- MoveIt
Courses and programs
Professional training
Programs for engineers that I developed at STANKIN:
- Industrial manipulator robots: modern technologies and applications
- Intelligent systems in industrial robotics
- Unmanned aerial systems
- ROS 2 fundamentals
English-taught course
“Programming and Operation of Industrial Robots”: programming and operating ABB robots, offline programming in RobotStudio. Taught abroad.
Patents and publications
-
Russian patent RU 2869712 C1, 2026
Method for controlling the joint motion of a heterogeneous multi-agent system
-
Registered software RU 2025695805, 2025
User container management module for a robotics education platform (server side)
-
Registered software RU 2023685496, 2023
Lighting intensity controller (LIV controller)
-
Article, 2019
Modeling the worm-like motion of a snake robot with dynamics
-
Accelerators, 2023
NTI Accelerator and Phystech.Aero
For students
I supervise student theses. These are the topics I am most interested in right now:
- computer vision and neural networks for tracking moving objects;
- control systems for pan-tilt and tracking devices;
- industrial and collaborative robots: programming, robotic cells, simulation;
- mobile robots on ROS 2: navigation, localization, simulation;
- space robotics.
I meet each thesis student once a week. Students keep all their work in a GitHub repository based on a template; finished projects are collected in vkr-robotics.
How do I choose a topic?
Pick one of the topics above or propose your own. We refine it at the first meeting so that it interests you and fits the time you have.
What should I prepare for the first meeting?
A few words about yourself: what you have built, which languages and tools you know, what you would like to try. If you have a GitHub account, send me the link.
How does the work go?
We meet once a week, review what is done and set tasks for the next week. Code, calculations, drafts and notes live in a repository based on the template, so we both see the progress.
If you would like to do your thesis with me, message me on Telegram: who you are, where you study, and what topic interests you. You can also propose your own.
Mentions
- Author of the professional training program “Industrial Manipulator Robots: Modern Technologies and Applications” STANKIN professional education site
- Presented the design of robotic systems for processing large curved surfaces at the Marine Robotics strategic session in Murmansk STANKIN Telegram channel
- Expert on the science show “First in Science. Robotics”: where to study robotics and how robots are built (in Russian) VK Video
- Spoke at an Almaz-Antey conference on factory robotization: how a university can help, from audits and R&D to deploying robotic cells and training staff STANKIN Telegram channel
- Gave a public lecture “Robots in Space” for Cosmonautics Day STANKIN Telegram channel
- Presented STANKIN’s Youth Project Center at the student design bureaus forum at Bauman University STANKIN Telegram channel
- Represented STANKIN at a Sber strategic session on the future of educational robotics in Russia STANKIN Telegram channel